
493 lines
20 KiB
JSON
493 lines
20 KiB
JSON
[
|
||
{
|
||
"id": 1,
|
||
"q": "RDK 开发板的 40PIN GPIO 引脚是多少伏的电平标准?最大耐受电压是多少?",
|
||
"ml": {
|
||
"latency": 7.61,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"40pin_define.md",
|
||
"uart.md",
|
||
"rdk_x5.md",
|
||
"spi.md"
|
||
],
|
||
"snippet": "---\ntitle: 管脚定义与应用\nurl: https://developer.d-robotics.cc/rdk_doc/Basic_Application/01_40pin_user_sample/40pin_define\nsource_type: markdown\narea: rdk_user_manual\nlanguage: zh\n---\n\n\n# 管脚定义与应用\n\n开发板上的 40PIN 功能管脚,接口定义请查看本章节。\n\n## 硬件使用说明\n\n - RDK上的40PIN,提供的GPIO均为3.3V逻辑信号,其最大耐压为3.46V。\n - RDK上的40PIN,其3.3V最大支持8",
|
||
"hit_must": true
|
||
},
|
||
"m0": {
|
||
"latency": 0.96,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "User noted that the 40PIN GPIO pins on the RDK development board operate at 3.3 V logic level with a maximum voltage rating of 3.46 V",
|
||
"score": 0.7068,
|
||
"src": "40pin_define.md"
|
||
},
|
||
{
|
||
"memory": "User noted that the 40PIN GPIO pins on the RDK board can supply up to 800 mA at 3.3 V and up to 500 mA at 5 V, and that the board’s power adapter must support at least 25 W under load.",
|
||
"score": 0.6377,
|
||
"src": "核心开发文档/基础应用开发/40pin_define.md"
|
||
},
|
||
{
|
||
"memory": "User explained that on RDK X5, the 40PIN interfaces share multiplexed functions where only one function in a group can be enabled at a time, and the pins act as ordinary GPIO only when all multiplexed",
|
||
"score": 0.5904,
|
||
"src": "核心开发文档/基础应用开发/40pin_define.md"
|
||
}
|
||
],
|
||
"hit_must": true
|
||
}
|
||
},
|
||
{
|
||
"id": 2,
|
||
"q": "RDK 的 I2C 驱动是怎么开发的?设备树要怎么配置?",
|
||
"ml": {
|
||
"latency": 4.99,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"driver_i2c_dev.md",
|
||
"driver_i2c_dev.md",
|
||
"rdk_x3.md",
|
||
"hardware_and_system.md"
|
||
],
|
||
"snippet": "---\ntitle: I2C调试指南\nurl: https://developer.d-robotics.cc/rdk_doc/Advanced_development/linux_development/driver_development/driver_i2c_dev\nsource_type: markdown\narea: rdk_user_manual\nlanguage: zh\n---\n\n\n# I2C调试指南\n\n## 前言\n\nX3芯片提供了标准的I2C总线,I2C总线控制器通过串行数据线(SDA)和串行时钟(SCL)线在连接到总线的器件间传递信息。 每个器件都有一个唯一的地址(无论是微控"
|
||
},
|
||
"m0": {
|
||
"latency": 1.24,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "DTS 中的 i2c 节点主要声明寄存器、时钟和中断等 SoC 通用资源,通常不需要针对具体电路板进行修改",
|
||
"score": 0.6474,
|
||
"src": "驱动与硬件/驱动开发/driver_i2c_dev.md"
|
||
},
|
||
{
|
||
"memory": "The I2C driver source files are drivers/i2c/i2c-dev.c (character‑device interface), drivers/i2c/i2c-core-base.c (framework), and drivers/i2c/busses/i2c-designware-platdrv.c (DesignWare driver).",
|
||
"score": 0.5654,
|
||
"src": "驱动与硬件/驱动开发_x5/driver_i2c_dev.md"
|
||
},
|
||
{
|
||
"memory": "User‑space I2C devices are accessed via /dev/i2c‑%d interfaces, with detailed usage described in Documentation/i2c/dev‑interface.",
|
||
"score": 0.5266,
|
||
"src": "驱动与硬件/驱动开发_x5/driver_i2c_dev.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 3,
|
||
"q": "RDK 开发板的 CAN 总线如何配置和使用?",
|
||
"ml": {
|
||
"latency": 3.73,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"can.md",
|
||
"INDEX.md",
|
||
"srpi-config.md",
|
||
"40pin_define.md"
|
||
],
|
||
"snippet": "0 123#1122334455667788\n```\n\n测试结果: 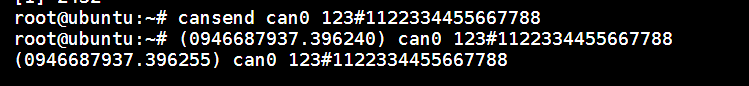\n\n### CANFD回环测试\n\n仲裁段波特率为500K,数据场波特率为2M\n\n```\nip link set can0 downip link set can0 type can bitrate 500000 dbitrate 2000000"
|
||
},
|
||
"m0": {
|
||
"latency": 0.99,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "The self‑start configuration document for RDK boards (title: 2.5 开机自启动配置) was last updated on 2026‑06‑14",
|
||
"score": 0.6292,
|
||
"src": "系统与启动/系统配置/self_start.md"
|
||
},
|
||
{
|
||
"memory": "User provided a technical document titled \"6. 应用开发指南\" with URL https://developer.d-robotics.cc/rdk_doc/Application_case, classified as markdown in the rdk_user_manual area and written in Chinese",
|
||
"score": 0.3998,
|
||
"src": "代码示例/Application_case.md"
|
||
},
|
||
{
|
||
"memory": "User describes the \"基础应用开发\" (Basic Application Development) category as containing 17 files, among them 40pin_define.md (hardware interface must‑read), uart.md, spi.md, usb_camera.md, vio_capture.md, ",
|
||
"score": 0.3995,
|
||
"src": "INDEX.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 4,
|
||
"q": "RDK 的 BPU 如何进行模型推理?",
|
||
"ml": {
|
||
"latency": 4.16,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"infer_api_ref.md",
|
||
"python_api.md",
|
||
"fcos.md",
|
||
"bpu.md"
|
||
],
|
||
"snippet": "` 导入。\n\nRDK X3 使用 `bpu_infer_lib_x3` wheel,`rdk_x5_legacy` 分支使用 `bpu_infer_lib_x5` wheel。\n 警告\n`bpu_infer_lib` **对 featuremap 输入模型支持不佳**。如需使用 featuremap 输入模型,请使用 `hbm_runtime` 推理接口(RDK X5 或 RDK S 系列)。\n\n### 安装\n\nRDK X3:\n\n```\nwget -nc https://archive.d-robotics.cc/downloads/rdk_model_zoo/rdk_x3/bpu_infer"
|
||
},
|
||
"m0": {
|
||
"latency": 1.01,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "RDK X3 的源码托管在 GitHub 的 rdk-gen 仓库,仓库的 README 提供了详细的开发环境配置指南。",
|
||
"score": 0.5713,
|
||
"src": "核心开发文档/工具链与构建/environment_build.md"
|
||
},
|
||
{
|
||
"memory": "User provided a C language BPU example located at /app/cdev_demo/bpu, illustrating how to invoke BPU‑supported models with C code.",
|
||
"score": 0.3482,
|
||
"src": "核心开发文档/基础应用开发/bpu.md"
|
||
},
|
||
{
|
||
"memory": "A complete list of operators supported by D‑Robotics processors is available in the ‘模型算子支持列表’ chapter at https://developer.d-robotics.cc/rdk_doc/Advanced_development/toolchain_development/intermediat",
|
||
"score": 0.3938,
|
||
"src": "核心开发文档/进阶开发/overview.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 5,
|
||
"q": "RDK 的 ISP 系统是怎么工作的?pipeline 是怎样的?",
|
||
"ml": {
|
||
"latency": 3.23,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"isp_system.md",
|
||
"debug_info.md",
|
||
"performance_debug.md",
|
||
"system_control.md"
|
||
],
|
||
"snippet": "---\ntitle: 7.3.5 ISP图像系统\nurl: https://developer.d-robotics.cc/rdk_doc/Advanced_development/multimedia_development/isp_system\nsource_type: markdown\narea: rdk_user_manual\nlanguage: zh\n---\n\n\n# 7.3.5 ISP图像系统\n\n## 概述\n\n### AE\n\nAE算法通过分析直方图进行操作,以计算相对于校准中设置的AE target的新EV值。AE target由算法动态控制,以确保正确曝光低动态范围场景和高动态范围"
|
||
},
|
||
"m0": {
|
||
"latency": 1.31,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "RDK X3 的源码托管在 GitHub 的 rdk-gen 仓库,仓库的 README 提供了详细的开发环境配置指南。",
|
||
"score": 0.605,
|
||
"src": "核心开发文档/工具链与构建/environment_build.md"
|
||
},
|
||
{
|
||
"memory": "DTS 中的 i2c 节点主要声明寄存器、时钟和中断等 SoC 通用资源,通常不需要针对具体电路板进行修改",
|
||
"score": 0.398,
|
||
"src": "驱动与硬件/驱动开发/driver_i2c_dev.md"
|
||
},
|
||
{
|
||
"memory": "Struct VIN_DEV_OUTPUT_ISP_S defines ISP output attributes: dol_exp_num, enable_dgain, set_dgain_short, set_dgain_medium, set_dgain_long, short_maxexp_lines, medium_maxexp_lines, vc_short_seq, vc_mediu",
|
||
"score": 0.3115,
|
||
"src": "算法与多媒体/多媒体/video_input.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 6,
|
||
"q": "RDK 视频编码支持哪些格式?H.265 编码怎么设置码率?",
|
||
"ml": {
|
||
"latency": 7.74,
|
||
"n": 10,
|
||
"hit": true,
|
||
"docs": [
|
||
"video_encode.md",
|
||
"overview.md",
|
||
"video_input.md",
|
||
"vio2encoder.md"
|
||
],
|
||
"snippet": "---\ntitle: 7.3.9 视频编码\nurl: https://developer.d-robotics.cc/rdk_doc/Advanced_development/multimedia_development/video_encode\nsource_type: markdown\narea: rdk_user_manual\nlanguage: zh\n---\n\n\n# 7.3.9 视频编码\n\n## 概述\n\n视频编码模块实现H.264/H.265/JPEG/MJPEG协议硬件编码。该模块支持多通道实时编码,各通道相互独立,常见的使用场景,包括单路录像、多路录像、单路VIO视频流、多路VIO"
|
||
},
|
||
"m0": {
|
||
"latency": 1.55,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "i2c-tools 套件已交叉编译并随 X3J3 系统根文件系统提供,常用工具包括 i2cdetect、i2cdump、i2cget、i2cset、i2ctransfer,用于枚举、读取和写入 I2C 设备寄存器",
|
||
"score": 0.3971,
|
||
"src": "驱动与硬件/驱动开发/driver_i2c_dev.md"
|
||
},
|
||
{
|
||
"memory": "RDK X5 的源码托管在 GitHub 的 x5-rdk-gen 仓库,README 包含从环境安装到源码编译的完整说明。",
|
||
"score": 0.4,
|
||
"src": "核心开发文档/工具链与构建/environment_build.md"
|
||
},
|
||
{
|
||
"memory": "RDK Studio remote login steps: download RDK Studio, click “+ RDK 设备”, choose IP connection, select user type (sunrise for normal, root for super), fill device name and description, and confirm to add ",
|
||
"score": 0.3188,
|
||
"src": "系统与启动/快速开始/remote_login.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 7,
|
||
"q": "RDK 开发环境的工具链怎么搭建?交叉编译器如何配置?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.51,
|
||
"n": 10,
|
||
"hit": false,
|
||
"top": [
|
||
{
|
||
"memory": "RDK preparation steps: ensure USB camera works, connect to RDK USB slot, RDK runs Ubuntu 20.04/22.04 image, tros.b installed, and PC can access RDK over network",
|
||
"score": 0.3002,
|
||
"src": "算法与多媒体/机器人开发/demo_sensor.md"
|
||
},
|
||
{
|
||
"memory": "Preparation steps require the RDK to be pre‑flashed with the RDK OS, TogetheROS.Bot installed, and the PC able to access the RDK over the network",
|
||
"score": 0.2839,
|
||
"src": "算法与多媒体/机器人开发/stereo_imu_cam.md"
|
||
},
|
||
{
|
||
"memory": "RDK OS 1.x is a closed‑source legacy version that only supports early RDK X3 hardware",
|
||
"score": 0.2839,
|
||
"src": "调试与工具/FAQ/hardware_and_system.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 8,
|
||
"q": "RDK 的 UART 串口通信怎么开发?波特率怎么设置?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.54,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "User can remotely access the RDK development board via three methods: serial (UART) console, RDK Studio client, or network protocols (VNC and SSH).",
|
||
"score": 0.5348,
|
||
"src": "系统与启动/快速开始/remote_login.md"
|
||
},
|
||
{
|
||
"memory": "User states that the RDK X3 chip provides four UART ports: UART0, UART1, UART2, and UART3; UART0 is used as the debug serial port, and only UART1 supports hardware flow control.",
|
||
"score": 0.4724,
|
||
"src": "驱动与硬件/驱动开发/driver_uart_dev.md"
|
||
},
|
||
{
|
||
"memory": "User mentions that the RDK X3 Module provides a debug serial (interface 15) via a CH340 chip, using the same UART parameters and requiring CH340 driver installation",
|
||
"score": 0.4735,
|
||
"src": "硬件规格书/板卡介绍/rdk_x3.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 9,
|
||
"q": "RDK 支持哪些 IMU 模块?怎么读取数据?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.49,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "The documentation for the RDK IMU Module was last updated on 2026‑06‑14",
|
||
"score": 0.6984,
|
||
"src": "核心开发文档/基础应用开发/rdk_imu_module.md"
|
||
},
|
||
{
|
||
"memory": "RDK IMU Module uses Bosch BMI088 sensor, providing a 3‑axis gyroscope and 3‑axis accelerometer, and can connect to the RDK board via I2C or SPI, with data accessible through the Linux IIO subsystem",
|
||
"score": 0.6094,
|
||
"src": "核心开发文档/基础应用开发/rdk_imu_module.md"
|
||
},
|
||
{
|
||
"memory": "After confirming the system version, run `srpi-config` on the RDK X5, reboot, and verify that `/sys/bus/iio/devices/` contains `iio:device1` and `iio:device2`, indicating successful IMU configuration",
|
||
"score": 0.5246,
|
||
"src": "算法与多媒体/机器人开发/stereo_imu_cam.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 10,
|
||
"q": "RDK 的 PWM 输出怎么控制?占空比和频率如何设置?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.95,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "PWM/pwmchip correspondence can be queried by reading /sys/class/pwm/pwmchip*/device/uevent, which shows DRIVER, OF_NAME, OF_FULLNAME and other identifiers for each PWM instance",
|
||
"score": 0.5524,
|
||
"src": "驱动与硬件/驱动开发_x5/driver_pwm.md"
|
||
},
|
||
{
|
||
"memory": "To enable PWM support in the kernel, the configuration path is Device Drivers → Pulse‑Width Modulation (PWM) Support → Hobot PWM controller support → Hobot lite PWM controller support",
|
||
"score": 0.5499,
|
||
"src": "驱动与硬件/驱动开发/driver_pwm_dev.md"
|
||
},
|
||
{
|
||
"memory": "User can test PWM via sysfs: export pwm0‑2 under /sys/class/pwm/pwmchip0 (or 3), set period to 10000 µs, duty_cycle (e.g., 3000 µs for pwm0, 1000 µs for pwm1/2), and write 1 to enable",
|
||
"score": 0.5056,
|
||
"src": "驱动与硬件/驱动开发/driver_pwm_dev.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 11,
|
||
"q": "RDK X5 的低功耗模式怎么配置?休眠唤醒流程是什么?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.48,
|
||
"n": 10,
|
||
"hit": false,
|
||
"top": [
|
||
{
|
||
"memory": "User lists a metal full‑metal case for RDK X5 from 地瓜机器人 (RDK X5 Case) and an IEEE 802.3af/at PoE module (RDK X5 PoE Module) with 40‑PIN GPIO, isolated SMPS, fan and heatsink",
|
||
"score": 0.4753,
|
||
"src": "系统与启动/快速开始/accessory.md"
|
||
},
|
||
{
|
||
"memory": "The module is intended for RDK X5 and RDK X5 Module platforms, and the recommended system image version is 3.4.x (compatible with 3.5.x)",
|
||
"score": 0.4756,
|
||
"src": "核心开发文档/基础应用开发/rdk_imu_module.md"
|
||
},
|
||
{
|
||
"memory": "RDK X5 and RDK X5 Module offer interfaces for Ethernet, USB, cameras, LCD, HDMI, CANFD, and a 40‑PIN header for image, multimedia, and deep‑learning application development.",
|
||
"score": 0.4357,
|
||
"src": "硬件规格书/板卡介绍/rdk_x5.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 12,
|
||
"q": "RDK 的音频驱动 ES8326 怎么调试?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.81,
|
||
"n": 10,
|
||
"hit": false,
|
||
"top": [
|
||
{
|
||
"memory": "The self‑start configuration document for RDK boards (title: 2.5 开机自启动配置) was last updated on 2026‑06‑14",
|
||
"score": 0.4345,
|
||
"src": "系统与启动/系统配置/self_start.md"
|
||
},
|
||
{
|
||
"memory": "RDK X3 的源码托管在 GitHub 的 rdk-gen 仓库,仓库的 README 提供了详细的开发环境配置指南。",
|
||
"score": 0.3545,
|
||
"src": "核心开发文档/工具链与构建/environment_build.md"
|
||
},
|
||
{
|
||
"memory": "RDK X5 的源码托管在 GitHub 的 x5-rdk-gen 仓库,README 包含从环境安装到源码编译的完整说明。",
|
||
"score": 0.3444,
|
||
"src": "核心开发文档/工具链与构建/environment_build.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 13,
|
||
"q": "RDK 怎么用 Python 写应用?有没有代码示例?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 1.01,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "YOLOv8 deployment on RDK X3 with Python multiprocessing for 30 fps is documented in a CSDN blog (link provided in the FAQ)",
|
||
"score": 0.5264,
|
||
"src": "核心开发文档/工具链与构建/toolchain.md"
|
||
},
|
||
{
|
||
"memory": "User explains that third‑party libraries can be installed directly on the RDK board if they provide ARM‑compatible .deb packages or can be installed via apt, and Python packages can be installed with ",
|
||
"score": 0.5076,
|
||
"src": "代码示例/applications_and_examples.md"
|
||
},
|
||
{
|
||
"memory": "User shared a Python sample documentation for the RDK S100 platform that provides AI example programs covering image classification, object detection, semantic segmentation, instance segmentation, pos",
|
||
"score": 0.4905,
|
||
"src": "代码示例/python/python_sample.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 14,
|
||
"q": "RDK 的 RTC 实时时钟驱动怎么开发?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.51,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "User notes that the PCF8563 RTC driver source file is located at drivers/rtc/rtc-pcf8563.c in the kernel tree",
|
||
"score": 0.5886,
|
||
"src": "驱动与硬件/驱动开发/driver_rtc_dev.md"
|
||
},
|
||
{
|
||
"memory": "User explains that after the driver loads, the RTC appears as the device node /dev/rtc1, and a symbolic link can be created to /dev/rtc using ln -sf /dev/rtc1 /dev/rtc",
|
||
"score": 0.5731,
|
||
"src": "驱动与硬件/驱动开发/driver_rtc_dev.md"
|
||
},
|
||
{
|
||
"memory": "User provides test commands for the RTC: set system time with `date -s 2022.01.21-21:24:00`, write system time to the RTC with `hwclock -w`, read RTC time with `hwclock -r`, synchronize RTC to system ",
|
||
"score": 0.5322,
|
||
"src": "驱动与硬件/驱动开发/driver_rtc_dev.md"
|
||
}
|
||
]
|
||
}
|
||
},
|
||
{
|
||
"id": 15,
|
||
"q": "RDK 的 RTSP 视频流怎么拉流显示到屏幕?",
|
||
"ml": {
|
||
"error": "POST https://app.memorylake.ai/openapi/memorylake/api/v1/projects/proj-916e44676bf249c49e19a93884461de3/documents/search failed: HTTP 402"
|
||
},
|
||
"m0": {
|
||
"latency": 0.57,
|
||
"n": 10,
|
||
"hit": true,
|
||
"top": [
|
||
{
|
||
"memory": "VLC is not recommended for RTSP streaming to RDK boards because it may not ensure PPS and SPS are present; use ffmpeg or other professional streaming tools instead",
|
||
"score": 0.4973,
|
||
"src": "调试与工具/FAQ/multimedia.md"
|
||
},
|
||
{
|
||
"memory": "RDK boards currently support decoding RTSP video streams up to 1080p (1920×1080) resolution; higher resolutions may not be supported",
|
||
"score": 0.4912,
|
||
"src": "调试与工具/FAQ/multimedia.md"
|
||
},
|
||
{
|
||
"memory": "When using ffmpeg to push an RTSP stream to an RDK board, add the option `-bsf:v h264_mp4toannexb` (or older `-vbsf`) to insert PPS and SPS parameters",
|
||
"score": 0.4632,
|
||
"src": "调试与工具/FAQ/multimedia.md"
|
||
}
|
||
]
|
||
}
|
||
}
|
||
] |